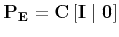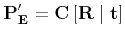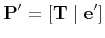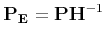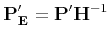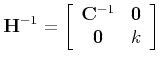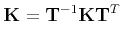- Suppose that
![$\displaystyle {\bf P_E} = {\bf C}\left[ {\bf I} \mid {\bf0} \right]$](img117.png)
and
i.e., we assume that the two camera positions have fixed internals.
- Suppose, also, that we have recovered affine structure
and a pair of projection matrices
![$\displaystyle {\bf P} = \left[ {\bf I} \mid {\bf0} \right]
$](img61.png)
and
- Then we know that
.
- We also know that

and
where,
is the affine transformation that upgrades the affine reconstruction
to Euclidean.
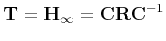
- The above gives us
- Rearranging and using
, we have
where
- Thus, the internal parameter matrix can be computed from
the infinite homography using Cholesky decomposition.
Subhashis Banerjee
2008-01-21