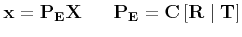Next: Camera calibration Up: Anatomy of a projective Previous: The Principal axis and
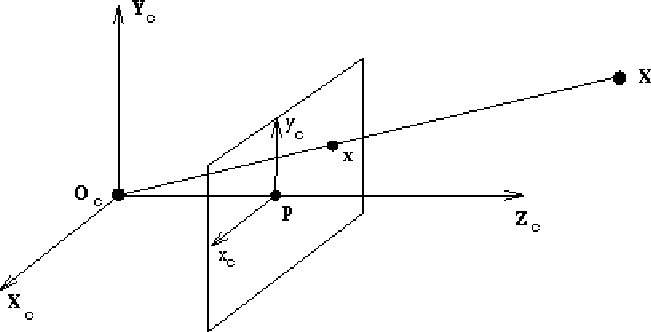
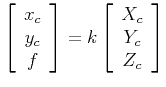
where
 . This can be written as
![$\displaystyle \left[ \begin{array}{c}x_c \\ y_c \\ f \end{array} \right] =
\lef...
...ray} \right]
\left[ \begin{array}{c}X_c \\ Y_c \\ Z_c \\ 1 \end{array} \right]
$](img312.png)
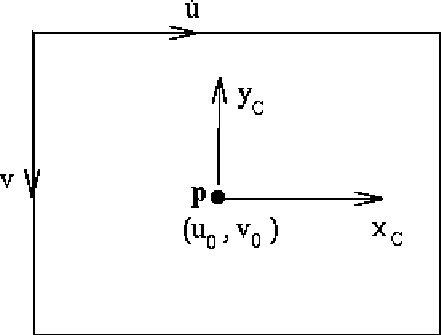
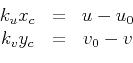
where the unit of
 's are pixel/length. This can be expressed as
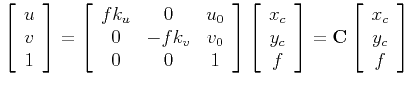
 is called the camera calibration matrix and it provides
the transformation between an image point and a ray in Euclidean 3-space.
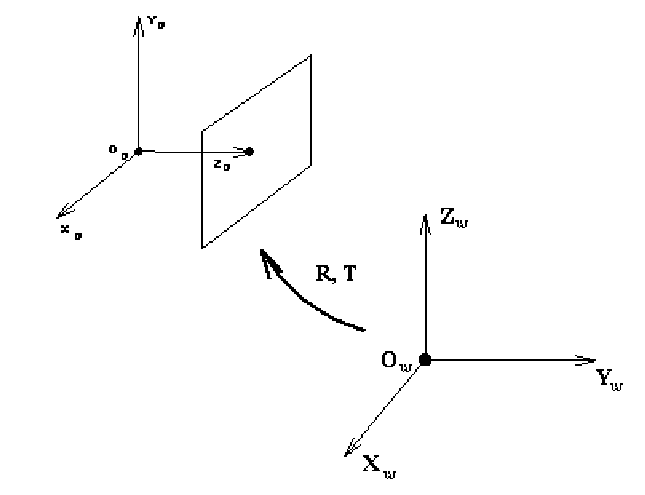
The Euclidean transformation between the camera and world coordinates is:
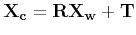
and is expressed projectively as:
![$\displaystyle \left[ \begin{array}{c}X_c \\ Y_c \\ Z_c \\ 1 \end{array} \right]...
...rray}\right]
\left[ \begin{array}{c}X_w \\ Y_w \\ Z_w \\ 1 \end{array} \right]
$](img319.png)
Finally, concatenating the three matrices, we have
![$\displaystyle \left[ \begin{array}{c}u \\ v \\ 1 \end{array} \right] =
{\bf C}\...
...f T} \right]
\left[ \begin{array}{c}X_w \\ Y_w \\ Z_w \\ 1 \end{array} \right]
$](img320.png)
which defines the
 projection from Euclidean
3-space to an image: